Projects / Research software
KITTI scene reconstruction
Rebuilding KITTI sequences in Unreal Engine 5 with matching camera and LiDAR models.
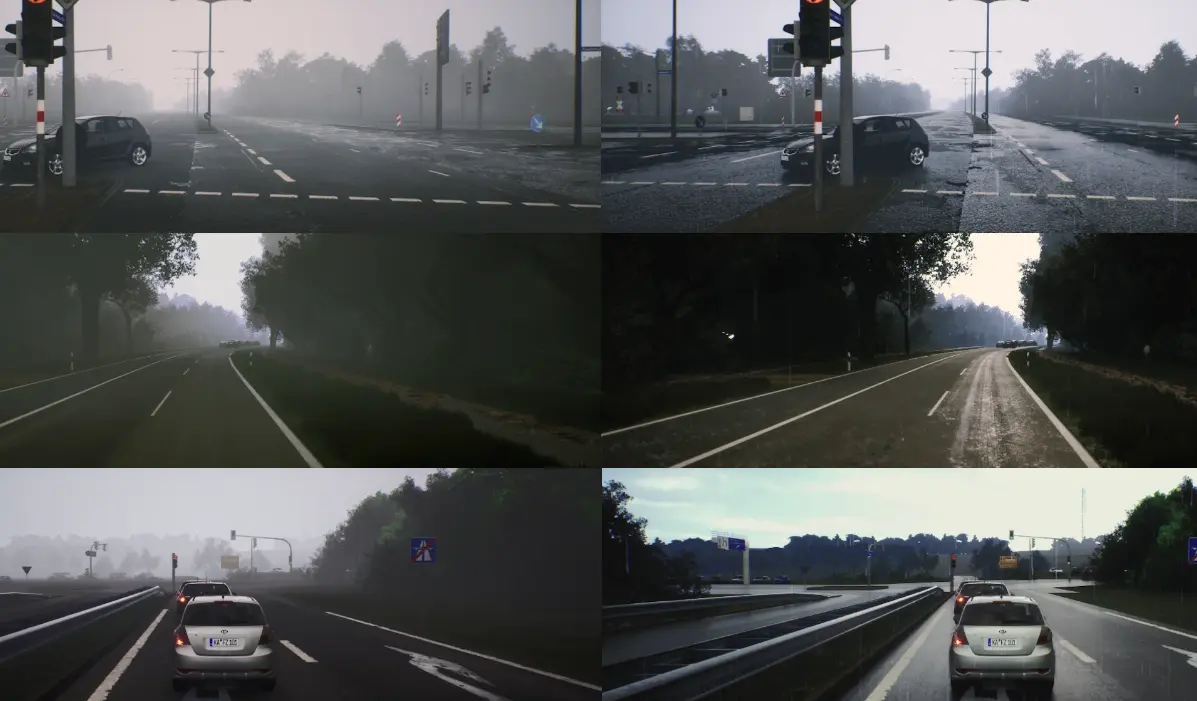
A pipeline that reconstructs recorded KITTI scenes so that simulated and real sensor data can be compared directly:
- photogrammetric reconstruction of the stereo images in Meshroom
- fusion and colourisation of the Velodyne point clouds with Open3D
- conversion of the tracklet annotations into world, camera and engine coordinates
- textured meshes and a viewer with playback and annotation overlay
In Unreal Engine the scenes use the exact KITTI camera parameters, rectified and unrectified models, Brown–Conrady lens distortion as a post-process material, and aligned LiDAR and camera frames.